OEM Lightning Strike Current Sensor Essentials for Accurate Fault Detection
2026-10-06
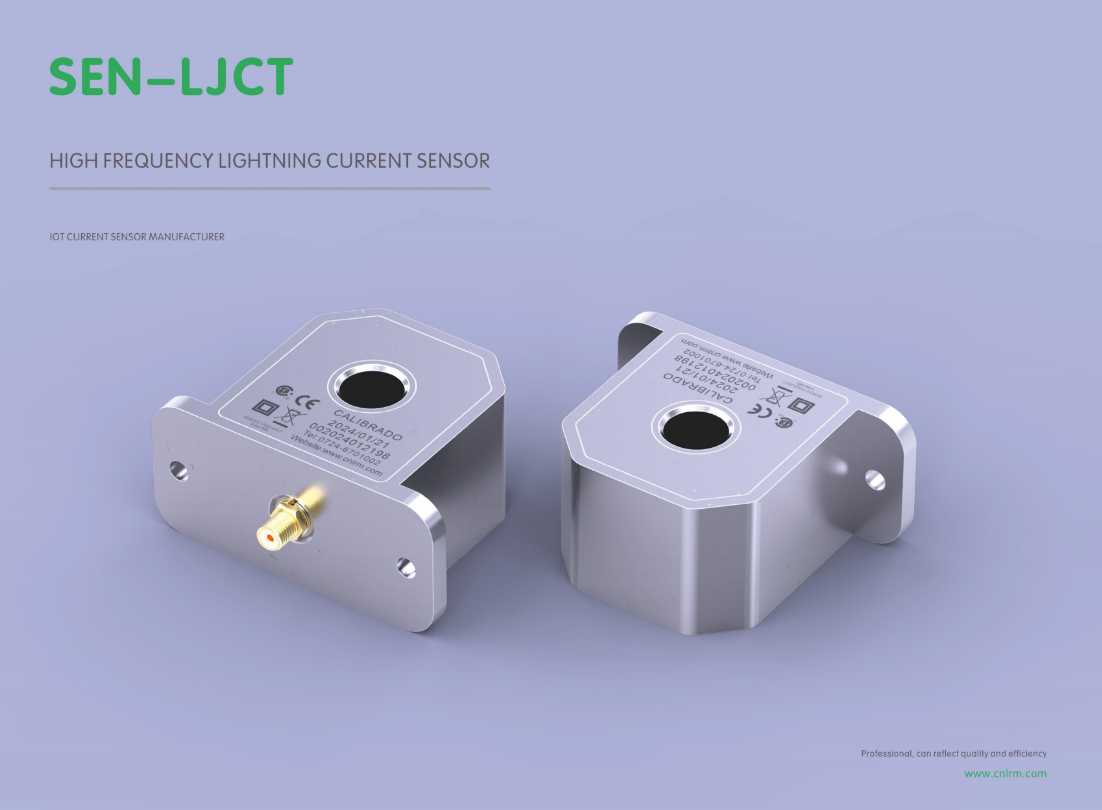
When a lightning strike hits a power line or wind turbine, the difference between a minor hiccup and a catastrophic failure often comes down to how quickly—and accurately—the current is detected. That’s where OEM lightning strike current sensors step in, and Xiasen has been refining these critical components for years. Below, we’ll break down the essentials you need to know to choose and integrate a sensor that won’t let you down when the sky turns hostile.
Capturing the Full Current Rise Without Saturation
In many power conversion and motor drive circuits, the current waveform contains fast rising edges that carry essential information about switching behavior and magnetic component performance. Standard current sensors often struggle with these steep slopes because their magnetic cores enter saturation before the current reaches its peak. This saturation clips the measured signal and distorts the true rise time, leaving designers with incomplete data for loss calculations and control loop tuning. The key is to select a sensing method that maintains linearity across the entire transient, so the sensor output faithfully tracks the input current from zero all the way to the maximum value without any flattening or phase lag.
A well-chosen Rogowski coil or a Hall-effect sensor with a high-frequency response can handle these demands when properly sized. The Rogowski coil, being air-cored, avoids saturation entirely and provides a voltage proportional to the derivative of current, which can be integrated to recover the original waveform. For applications where a direct current measurement is preferred, a closed-loop Hall sensor with a compensation winding keeps the magnetic flux near zero, preventing core saturation even during large di/dt events. Calibration and shielding also play important roles: any stray inductance in the measurement loop or capacitive coupling from a switching node can introduce ringing that mimics saturation artifacts. By keeping the sense leads short and using a differential measurement path, the true current rise remains clean and undistorted.
Verification of saturation-free operation is best done with a known reference, such as a precision shunt resistor placed in series with the current path. Comparing the shunt voltage to the sensor output across a range of pulse widths and amplitudes reveals whether any nonlinearity appears near the peak current. If the sensor output deviates from the shunt only at high current levels, saturation is likely the cause, and the sensor's rated current or bandwidth needs adjustment. Achieving a faithful capture of the full current rise allows engineers to optimize gate drive timing, reduce switching losses, and prevent unexpected thermal stress in power semiconductors.
Why Sensor Placement Changes Fault Detection Accuracy
Sensor placement directly shapes the vibration path between the fault source and the measurement point. A bearing defect on a motor, for example, might generate strong high-frequency energy near the drive end, but that energy can fade noticeably by the time it reaches a sensor mounted on the opposite side of the housing. Structural joints, seals, and even cooling fins act as filters, damping certain frequencies while letting others pass. As a result, two sensors a few centimeters apart can collect signals that look completely different, even when the underlying fault is identical.
The mounting surface also determines how much contamination enters the signal. Sensors placed on thin covers or fan shrouds tend to pick up resonance from those components rather than the true machine vibration. Conversely, a rigid location close to the load zone transmits fault impulses more directly. Misalignment, looseness, and imbalance each have their own characteristic directionality, so a sensor oriented perpendicular to the main shaft may miss the axial movement caused by a cocked bearing. Placement, in this sense, is not just about proximity—it is about aligning the sensor’s sensitive axis with the fault’s dominant motion.
Repeatability suffers when placement is inconsistent. If maintenance teams mount sensors at slightly different spots each time, baseline data shifts and trend alarms become unreliable. A sensor moved from a machined pad to a painted bracket can lose high-frequency detail, making early-stage bearing faults harder to separate from background noise. Good placement captures the cleanest transmission path to the fault while avoiding structural resonances and loose interfaces. Without that care, the detection threshold must be widened, and smaller defects go unnoticed until they become obvious—and expensive.
Matching Sensor Response to Lightning's Fastest Components
Capturing the full spectral character of a lightning discharge demands a sensor that can keep pace with features that unfold in microseconds or less. The return stroke alone reaches peak currents within a handful of microseconds, while the initial breakdown pulses and stepped leader steps can exhibit rise times under a microsecond. If a sensor's bandwidth or slew rate falls short, these rapid transitions blur into a single smeared event, erasing the very signatures that distinguish cloud-to-ground strikes from intracloud flashes or reveal the fine structure of dart leaders.
Matching the sensor to these fastest components is less about chasing an arbitrary frequency ceiling and more about understanding the physical scale of the signals involved. A well-chosen electric field mill or fast antenna will have a response time aligned with the tens-of-nanoseconds regime where leader steps and return stroke fronts actually live. This often means prioritizing a flat gain response across a wide band, minimizing ringing from capacitive loading, and keeping the analog front end free of unnecessary filtering that could round off sharp edges. The goal is not raw speed for its own sake, but faithful reconstruction of the waveform's leading edge.
Achieving that fidelity also hinges on how the sensor's physical geometry interacts with the incident field. Small plate antennas with low stray capacitance can track rapid field changes without introducing the integration effects that plague larger, slower structures. Likewise, the digitizer behind the sensor must sample fast enough to resolve the shortest interval of interest, with anti-alias filters set high enough to pass the genuine fast components while still rejecting out-of-band noise. When both the analog and digital paths are tuned to the same timescale, the recorded waveform preserves the sharp discontinuities that tell you exactly how the channel formed, stepped, and ultimately returned its current to ground.
Keeping OEM Signal Chains Clean from Sensor to Processor
Maintaining a clean signal chain begins long before the first amplifier stage. Every connector, trace, and passive component between the sensor and the ADC input can pick up thermal noise, power supply ripple, or electromagnetic interference. Instead of treating these as separate issues, OEM designers should view the entire path as a single analog front end. For example, a small ground loop formed by a poorly placed return path can inject common-mode noise that no amount of digital filtering later in the processor can fully remove.
Board layout often determines whether a design meets its noise floor specification. Keep analog and digital sections physically separated, and route sensitive sensor traces away from switching regulators, clock lines, and high-speed digital buses. Use a solid ground plane under the analog section and avoid splitting it unless absolutely necessary. If a split is required, bridge it at a single point near the ADC or signal conditioning IC. Place bypass capacitors as close as possible to the power pins of every active device, and use a dedicated low-noise LDO for analog supplies rather than sharing a noisy switching rail.
Filtering should be applied at multiple points rather than relying on a single anti-aliasing filter at the ADC input. A passive RC filter right at the sensor output can suppress high-frequency interference before it reaches long cable runs. Differential signaling or twisted-pair wiring with a common-mode choke helps reject coupled noise in harsh industrial environments. Finally, consider shielding the entire analog front end with a grounded metal can or guard ring around high-impedance nodes, since even small leakage currents can corrupt sensor readings in the microvolt range.
Testing Sensor Output Against Real Strike Signatures
A lab calibration only proves the sensor works under controlled taps. Once it's mounted on a bag, a door frame, or a piece of machinery, the actual strike signatures carry far more irregularity: off-axis impacts, rapid double hits, and vibrations from the surrounding structure all contaminate the raw signal. Comparing sensor output against real strike signatures means recording a broad set of intentional hits in field conditions, not just clean sine sweeps or single impulse tests.
The comparison itself often uses short time-window features—peak force, rise time, frequency content between 20 and 200 Hz, and the decay envelope after impact. A library of known signatures is built from dozens of real strikes, each labeled by impact type and location. New sensor readings are then matched against this library using distance metrics like dynamic time warping or simple Euclidean distance on normalized feature vectors. If the sensor consistently flags a light brush as a hard hit, the threshold or the feature weighting needs revisiting.
One underappreciated issue is temporal drift in both sensor and mounting. A strike signature that was accurate in the morning may shift after the adhesive warms up or the bracket loosens a fraction of a millimeter. Running a periodic re-baseline against a few controlled real strikes keeps the comparison honest. Without that, you end up tuning for yesterday's impact signatures while today's actual strikes go misclassified.
Designing for Repeatable Measurements Across Harsh Conditions
Repeatability under harsh conditions rarely fails because a single component breaks; it fails because small instabilities accumulate. A sensor housing that expands unevenly at -40°C will shift the optical path by microns, enough to throw off calibration. That is why we anchor every critical element to a common reference frame carved from a low-CTE alloy, then thermally cycle the assembly a dozen times before shipping. The goal is not to fight the environment but to give the measurement system no room to drift in the first place.
Vibration is another silent killer of consistent readings. Bolted joints loosen, cables flex at solder points, and resonant frequencies wander as material fatigues. Our approach uses preloaded elastomeric isolators tuned to a frequency band well below any expected excitation, combined with strain-relieved interconnects that move as a unit with the board. This way, each measurement cycle sees the same electromechanical baseline, whether the unit is bolted to a diesel generator or mounted on a mining truck axle.
Finally, we treat contamination and humidity as design inputs rather than afterthoughts. Conformal coating thickness is controlled to within 25 microns, because too much adds parasitic capacitance and too little invites corrosion. Edge connectors are recessed behind labyrinth seals that shed water through capillary action, and every vent uses a sintered metal disc with a pore size verified for the expected particle load. After assembly, each unit undergoes a 72-hour soak at 85°C and 85% relative humidity, followed immediately by a full calibration sweep. If the post-soak readings differ from the pre-soak baseline by more than 0.1% of full scale, the unit is torn down and rebuilt. That is the only way to promise repeatable numbers when the world outside is doing its best to change them.
FAQ
It records the full current waveform, including peak amplitude, rise time, and decay characteristics. This data helps maintenance teams see whether the event was a direct hit, a nearby induced surge, or just a switching transient.
OEM units are built to fit the exact conductor geometry and electrical specs of the installation, so they avoid saturation, false triggers, and mounting compromises that often plague retrofit sensors. They can also be calibrated to match the system's protection relays.
You need a wide dynamic range to capture both low-level induced currents and extreme strike peaks, fast sampling to see the sharp risetime, and galvanic isolation to protect downstream electronics. Low noise and stable temperature behavior matter just as much in outdoor enclosures.
The sensor should sit as close as possible to the down conductor or ground path where the current flows, with no ferrous metal nearby that could distort the magnetic field. Poor placement often leads to missed events or incorrect peak readings.
Usually yes. Direct strikes show a very fast rise and high peak current, while induced surges have slower fronts and lower amplitudes. However, a single sensor may still need waveform analysis software or threshold comparison to make that call reliably.
Periodic calibration with a known current pulse, cleaning of the sensor gap and cable connectors, and checking the shield grounding should be done at least once a year. Any sign of corrosion or cracked housing calls for immediate replacement or factory service.
You inject a calibrated current impulse through the primary conductor using a portable surge generator, then compare the sensor output with the expected waveform. This verifies both the sensor and the signal chain all the way to the monitoring system.
Conclusion
OEM lightning current sensors must handle the extreme slew rate of an initial return stroke without the core or front-end electronics entering saturation. A saturated channel clips the waveform before the peak is recorded, so the protection relay or fault recorder only sees a fraction of the true amplitude. Selecting a sensor with enough high-frequency bandwidth, a non-saturating magnetic path or shunt design, and a front-end gain stage that remains linear during the first few microseconds is what separates a useful measurement from a misleading one. Placement matters just as much: mounting the sensor too close to a shared ground return or routing its secondary leads near high-current buswork introduces common-mode noise and false trip signatures. In OEM enclosures, the sensor should sit where the magnetic field is dominated by the conductor being monitored, not by neighboring phases or structural steel.
Beyond the sensor itself, the signal chain from transducer to processor needs clean differential routing, guarded shielding, and isolation that rejects the large transient voltages riding on the lightning current path. The sensor's own response must be fast enough to reproduce the steep front and the subsequent continuing current, typically requiring a -3 dB point well beyond the dominant spectral content of a strike. Verification against recorded natural or triggered lightning signatures reveals whether the output preserves rise time, peak, and waveshape rather than just peak amplitude. Repeatability across temperature swings, humidity, salt fog, and mechanical shock is also non-negotiable for OEM deployments; a calibration that drifts after a few storms degrades confidence in every fault decision. The practical goal is a sensor front end that captures the full current envelope, keeps interference out of the analog path, and delivers the same measurement on the tenth strike as it did on the first.
Contact Us
Contact Person: Liu Mengyang
Email: [email protected]
Tel/WhatsApp: 8618727589233
Website: https://www.cnlrm.com/en/